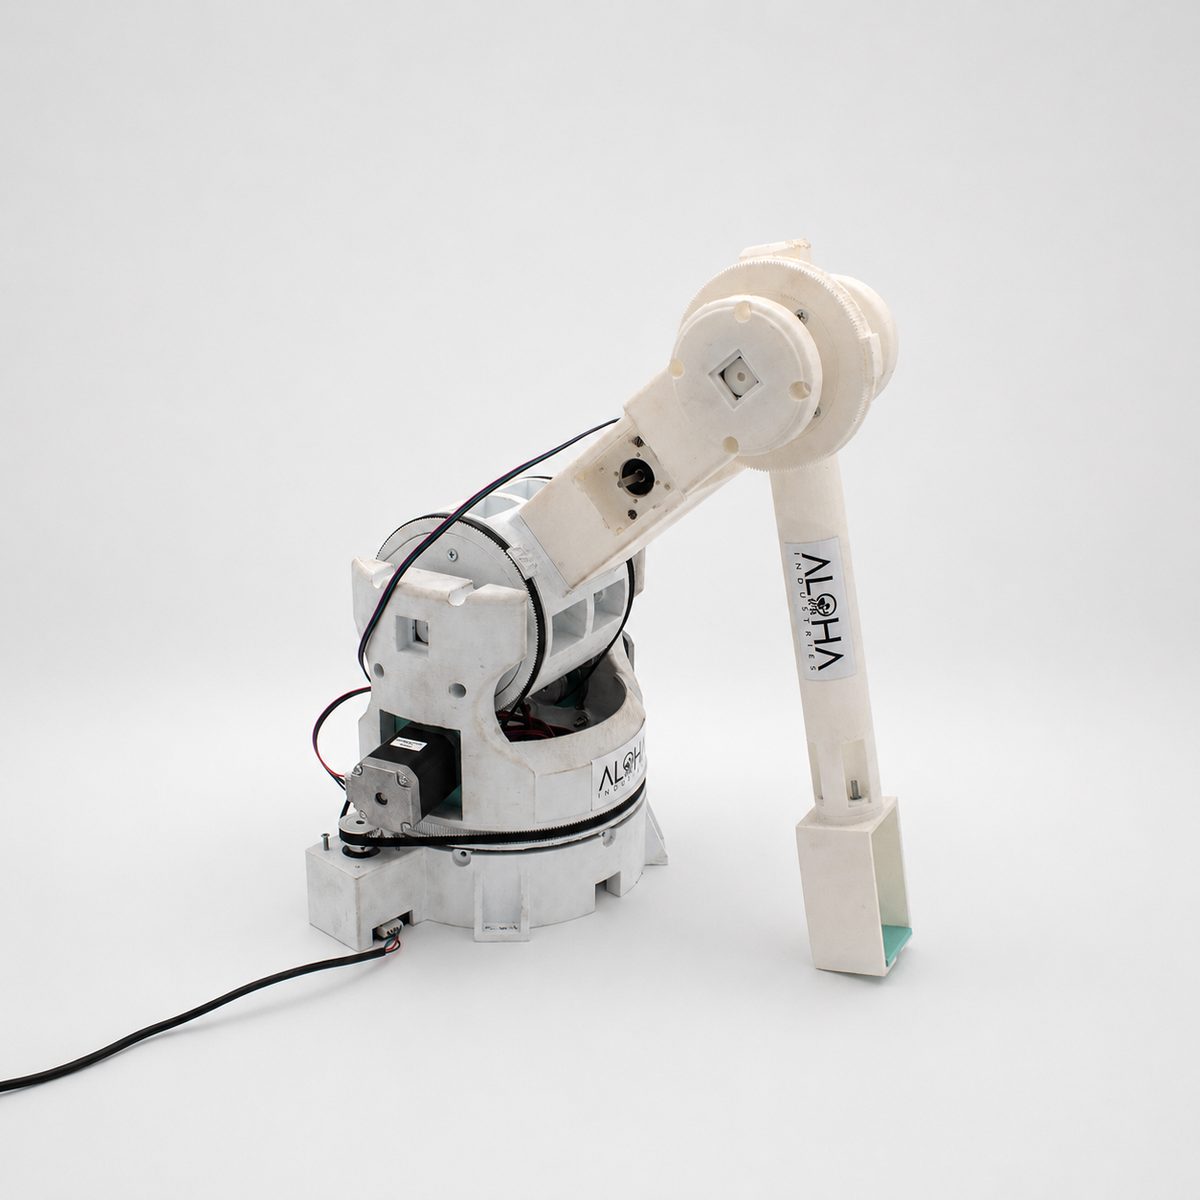
Multi-Axis Robotic Manipulator
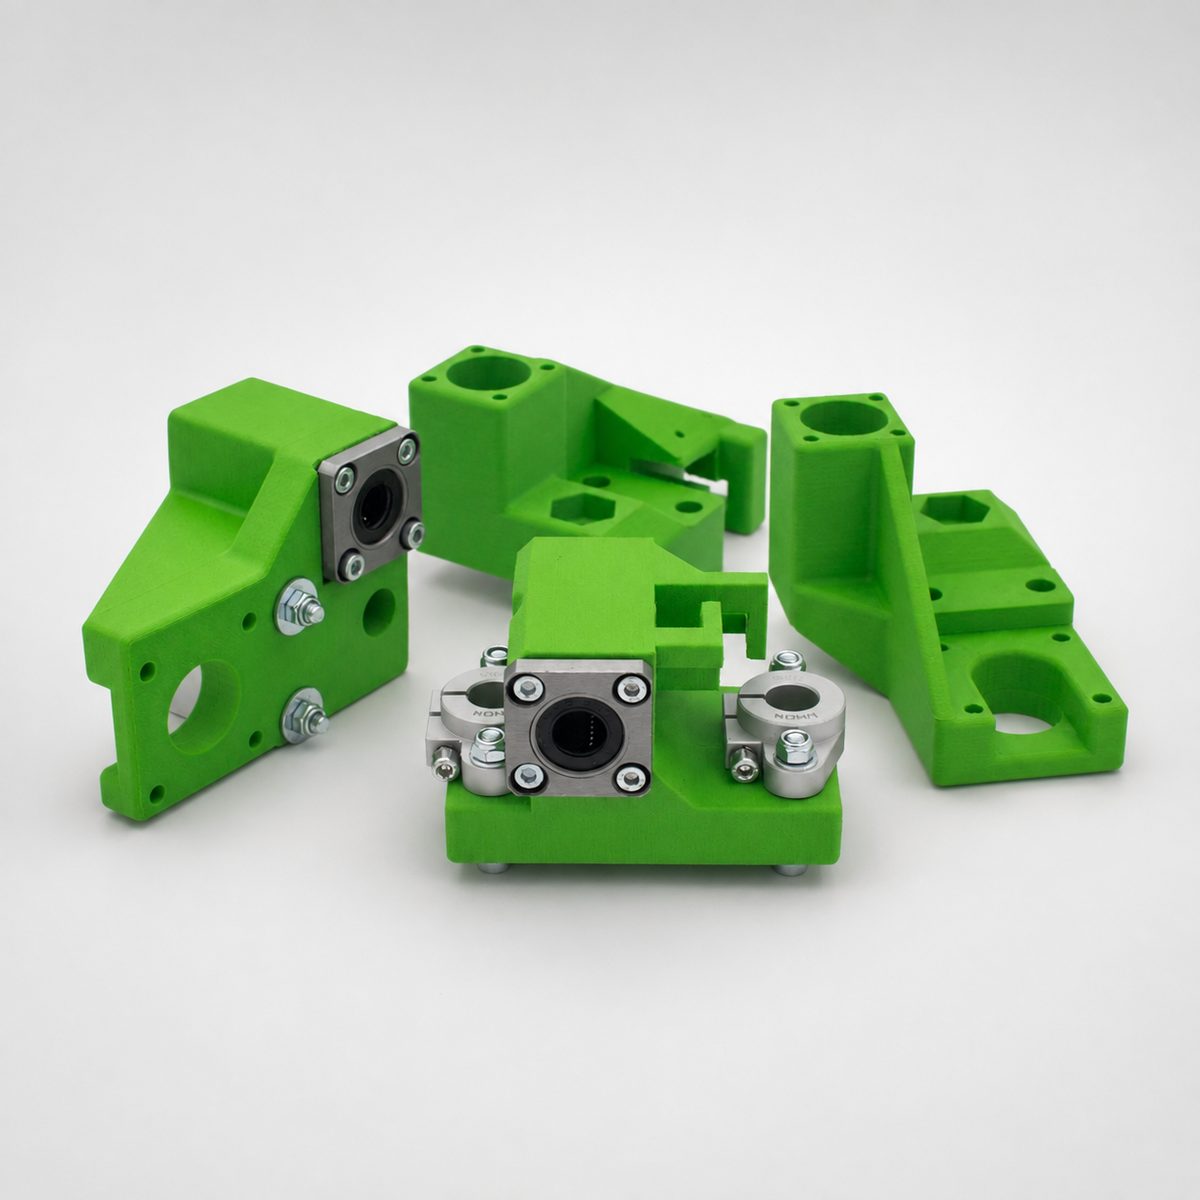
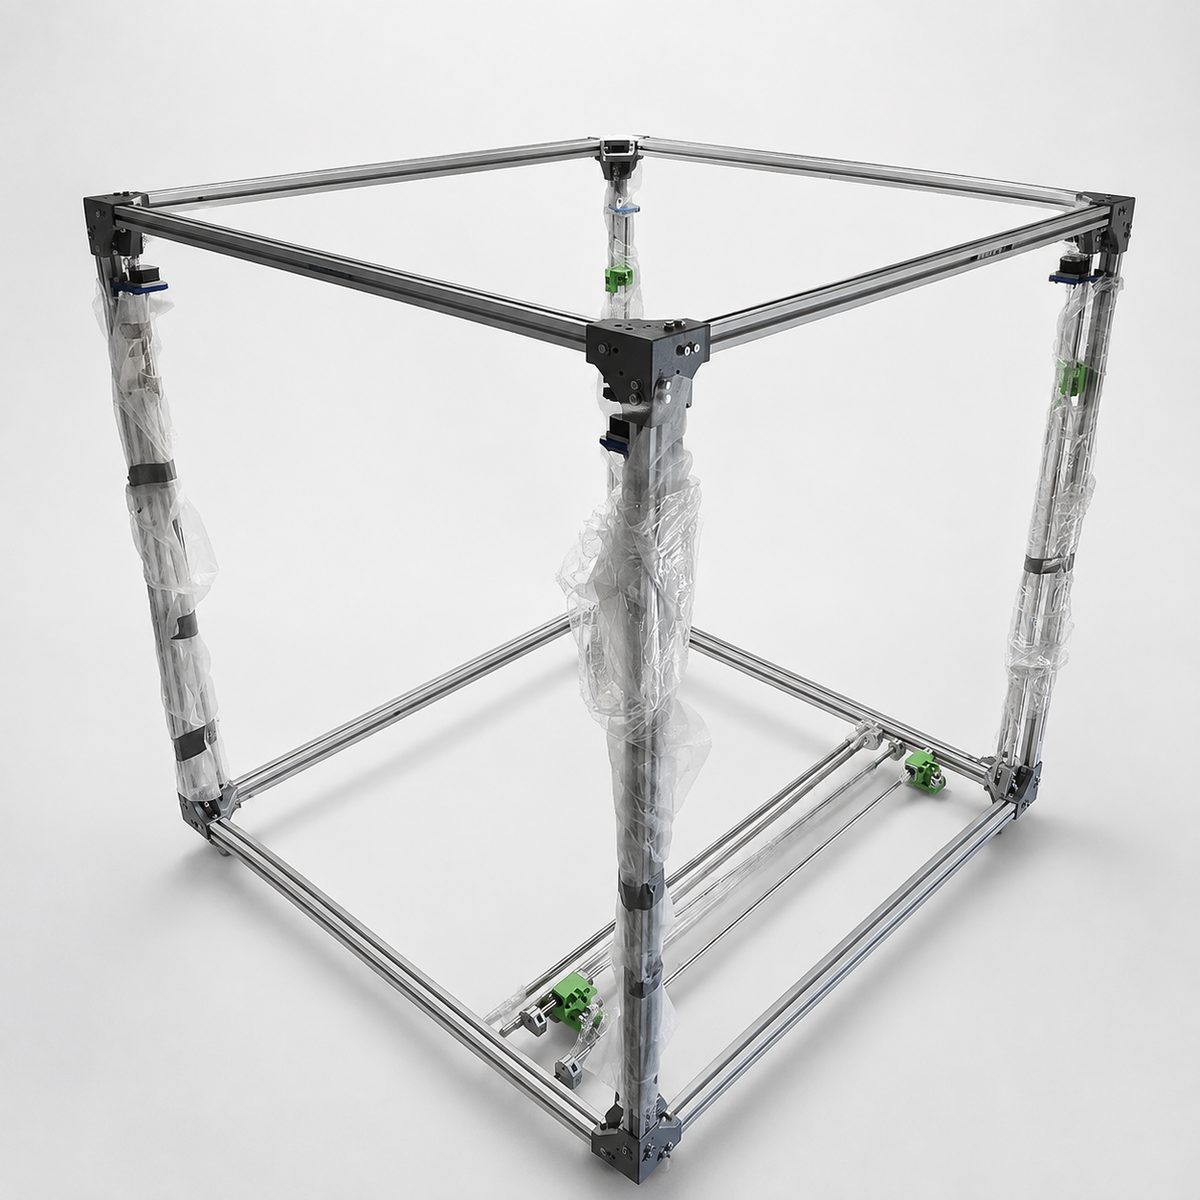
This ongoing development project explores the mechanical design and construction of a multi-axis robotic manipulator.
The structure must provide reliable movement and mechanical strength while remaining efficient to manufacture, assemble and refine through repeated prototype cycles.
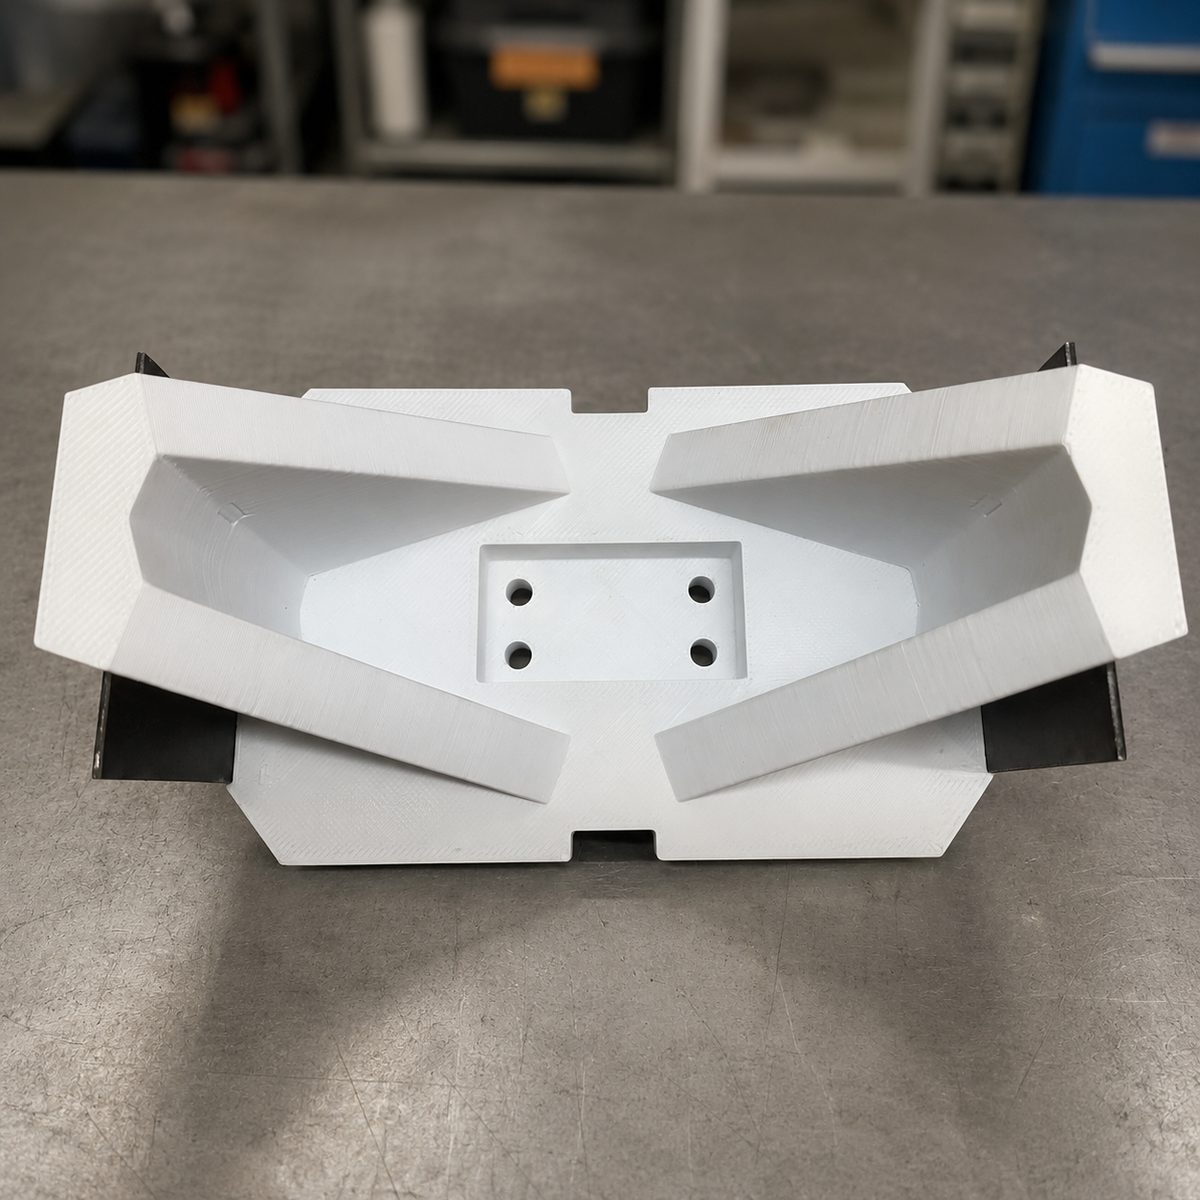
We are iterating the mechanical structure through multiple CAD and physical-prototype stages. Each version is reviewed for geometry, weight, material use, printability, assembly access and expected mechanical performance.
The project continues to progress through testing and optimisation. The objective is not only to produce a working mechanism, but a robust and manufacturable platform that can support future development.
Capabilities: robotics development, multi-part CAD assemblies, mechanical prototyping, additive manufacturing and design optimisation.